Some say that a drone (dron, UAV or RPAS) is nothing more than a flying machine that carries a camera… in a simplistic way, that’s true, but then it’s also true that all cameras are just mere data capture devices, and in turn, that the data is just noise that needs to be processed. In the end, It is a chain and all its links must work perfectly.. But let’s focus on the part of the sensors this time…
In the observation and surveillance missions with UAS (commonly referred to as ISR missions Given the acronyms Intelligence, Surveillance and Reconnaissance), the choice of the image sensor is fundamental. Both the selection and the integration of specific sensors or cameras for observation in unmanned aerial systems (UAS) are crucial. requires a well-measured balance between many limiting factors (which are not always obvious) taxes are imposed both by the aircraft itself, the capacity of the sensor itself, the operational characteristics of the aircraft, and even by the country's policies regarding the manufacture of the sensor.
The different missions that a UAS can perform have different requirements and even different objectives, so the range of requirements that define the best possible sensor is very wide.
Generally, what is always sought is Integrate the best possible sensor in an air system that is already quite Adapted and limited to a specific type of missions (For more details on the importance of mission-adapted design in a UAS, we recommend Read here the post “UAS and zero-sum systems”)
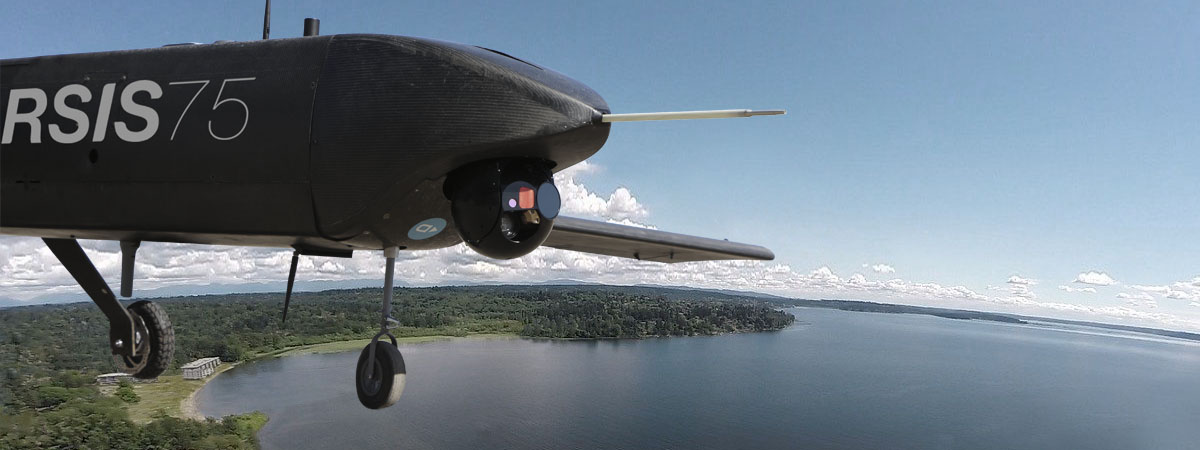
In the cases of UAS for observation missions, it is often crucial. that the image sensor is integrated into a gyrostabilized platform, ruggedized and with independent movements to the aircraft commonly called gimbal, ball or turret.
Since different missions have different constraints and since the same mission can have different objectives, the range of requirements that define the “best possible sensor” is extremely variable, but for practical and logical reasons an infinite range of them cannot be counted on and for this reason a compromise must always be reached in the choice of the same.
The choice of a sensor is based on many types of constraints imposed by the system, by the sensor itself, and even by the type of operation, as mentioned above.
The main limiting factors are:
Weight and size limitations. Obviously the sensor must have a spatial integration within the aircraft (although normally a part of the sensor usually protrudes outside the aircraft fuselage) that does not in an uncontrolled way alter its flight aerodynamics or pose a problem or a danger to other functions of the aircraft.
Similarly, the weight of the sensor must be within the load limits allowed by the aircraft. Only by taking this sensor weight factor into account can we encounter new positioning limitations. The sensor can only be placed in a limited range of positions so that the corresponding change in the aircraft’s center of gravity (CoG) remains within its allowable limits stipulated by the manufacturer’s design. Placing the sensor too far forward or too far back can inevitably lead to the loss of the aircraft in flight.
Communication, consumption and refrigeration limitations.
The sensor needs to communicate, be powered, and cooled. Cooling is usually not a problem for the part of the ball that protrudes outside the fuselage, but for the internal part, appropriate air inlets and outlets must be planned to prevent it from burning or shortening its lifespan.
The feeding and communication with other elements within the aircraft are resolved through the corresponding wiring, but it is also necessary to take into account their passage ducts, and the less obvious but almost inevitable signal shielding (produced by fasteners, metal plates or carbon fiber), possible areas of cross interference. Likewise, the connectors and contra-connectors that are not always optimized for this specific use must also be planned; for that reason, to provide greater reliability, they may end up being more bulky than desirable or planned.
Mechanical limitations of the sensor.
The main mechanical movements associated with a stabilized ball are called PTZ corresponding to Pan (horizontal movement of the camera), Tilt (vertical movement of the camera) and Zoom (movement of the camera lenses to increase or reduce their focal distance).
The first two require powerful and precise motors that take up space and must also be perfectly synchronized with each other to achieve smooth camera movement rather than jerky movements. The zoom motor usually comes built into the camera itself, but it must also be integrated at the control signal level.
In a good sensor, the horizontal rotation (Pan) capability should be 360º continuous, that is, it should be able to rotate indefinitely in one direction without the wires getting tangled around the axis. This is achieved by using electrical contacts that rotate around tracks on the axis…but this also requires more space and complexity than simply connecting the camera with cables.
As for the tilt, 90º are usually enough (to look from the horizon to the vertical) but something more is usually added both above the horizontal and beyond the vertical to compensate for the continuous pitching movements of the aircraft.
Limitations of rotation stabilization.
A sensor dedicated to observation and surveillance in UAS must be gyrostabilized by default.
This means two things:
First of all, the sensor must be isolated from unwanted movements such as vibrations typical of the aircraft structure produced by the engine, air friction and other disturbances. There is nothing worse than installing a high magnification capability for the image to be useless due to the movement the sensor is subjected to (the same effect as when looking at a distant point holding binoculars with trembling hands). This effect is usually mitigated by using mechanical insulators made of flexible material (like the silent blocks that isolate a car from the vibrations of its engine) placed between the ball and the aircraft structure; several stages of isolation may be necessary (i.e., even an isolated platform for vibrations of one type must be contained within another isolated platform for vibrations of another type).
The sensor must also be isolated from the normal motion of the corresponding aircraft, such as attitude corrections during roll, pitch and yaw for a stabilized flight, as well as from all movements necessary for a change in the flight path or those necessary to describe orbits over the target of interest.
Secondly, the sensor must have the ability to move independently of the aircraft through a control executed by the observer operator, allowing it to maintain its focus on a fixed or moving external point without being affected by the aircraft's attitude.
This is not only necessary for the image quality but also as a help to reduce the workload of the sensor operator.
The stabilization defined as the level of stabilization that the ball provides to the camera is measured in microradians and is performed by integrating accelerometers, magnetometers, and gyroscopes specific to the ball that maintain a stable positioning of the camera regardless of the attitude of the aircraft.
This stabilization is also performed or enhanced by the application of video processing algorithms that systematically compare consecutive frames of the captured video. When displacement differences appear between one frame and the next in a scene where no displacement should occur, the software conveniently reverses the X and Y motion axes while attempting to keep the image centered.
Image limitations.
An observation sensor that only provides a single video image in a single format may be too poor for most ISR missions. Ideally, the sensor should provide more than one type of image in addition to visual (electro-optical) imagery, such as infrared, to combine them into a process of object detection, recognition, and identification (DRI) that achieves greater power. It should also ideally include some zoom capability to allow, with the same camera, panoramic observation options along with detailed observation. And although they are not absolutely essential, other very useful options in observation missions are also valuable, such as laser rangefinders to establish precise distances to the target.
Limitations of functionality.
In a normal observation mission, the operator is obliged to be attentive to several screens at the same time (especially if the sensor transmits several types of images); this makes their workload and visual fatigue very high.
Some sensors incorporate automatic target generation functionalities that indicate to the operator all those objects that may be considered of interest for the operation. These functionalities are usually based on instantaneous image processes that can be performed on the same aerial platform or that require processing on land. In any case, that additional information must be able to be reflected and used on the ground station (GCS) screens immediately or quasi-real time. When the sensor performs the process, it must then be considered whether the processor is sufficiently small and powerful to fit on the gyrostabilized platform itself (this is the current trend) or whether (as in somewhat less evolved models) an external processor has to be onboard that must also be integrated.
The geotracking (communicating to the system some geographic coordinates so that the camera points to them in a stable manner) and videotracking (indicating on the received video image a fixed point of interest so that the camera points to that point in a stable manner) functionalities are highly appreciated in all observation missions. These functionalities require the sensor to be integrated with the same accelerometer and its coordination with a satellite positioning system (after all, what these functionalities do is assign GPS coordinates to the image that the camera would capture with a certain pan and tilt position according to the GPS coordinates in which the aircraft is located).
Operating limitations
Not all cameras are suitable for all missions. Obviously, the better the camera features, the greater variety of operations it can cover. Certain types of missions require certain types of cameras and capabilities… for example, in observation missions in wild or heavily foggy environments, several wavelengths are required, including short-wave infrared (SWIR) for which the water vapor gas clouds are transparent. Similarly, a purely visual sensor (Electro-Optical) is not capable of detecting anything in night missions.
Marketing restrictions.
The sensors we are talking about can be entered into restricted qualities or categories for defense uses that may prevent or limit their integration into a civilian use system. This is especially the case with high resolution IR cameras, where a HD resolution (720 pixels High Definition) is already considered to be intended solely for defense use and therefore its sale is regulated by the export regulations for dual-use materials. (Dual-use materials are items that, as is, or with minimal changes, can be used as weapons and are therefore regulated and controlled throughout their commercial journey through a final user certificate and the corresponding marketing permits required by the country of origin)
Manufacturer's service limitations
These high-power gyrostabilized sensors are usually quite expensive and are not always easy to integrate into another equally complex system like an UAS. That’s why it’s necessary to have manufacturers that have a minimum of flexibility in their conditions to start working with any of their products. Obviously, once the first unit is integrated, 90% of the issues with the subsequent units are resolved. That’s why the initial integrations require special attention and the availability of resources that, sometimes, are not within the integrator’s reach.
Political limitations
Not always the countries where dual-use components are purchased get along well with the countries to which the solution in which that component is integrated is intended. To make it more fun, these situations change over time and come and go according to the political relations between the three countries involved (the country of origin of the component, the country that performs the component integration, and the country of destination). So many times, a good component that meets all the requirements ends up being rejected because the country of origin maintains a dispute with the country of destination. The worst happens when this situation arises just at the moment when the component has already been acquired and integrated.
#uas